Exactly 23 printed pieces
- 18 common structural pieces—nine for each arm
- Two follower-specific gripper pieces
- Three leader-specific handle and wrist pieces
- Two controller plates—one for each arm
- Support removal, visual inspection and India delivery
Exactly 23 PLA+ pieces for a complete LeRobot-compatible SO-101 teleoperation pair: a leader arm for demonstration and a follower arm for executing motion.
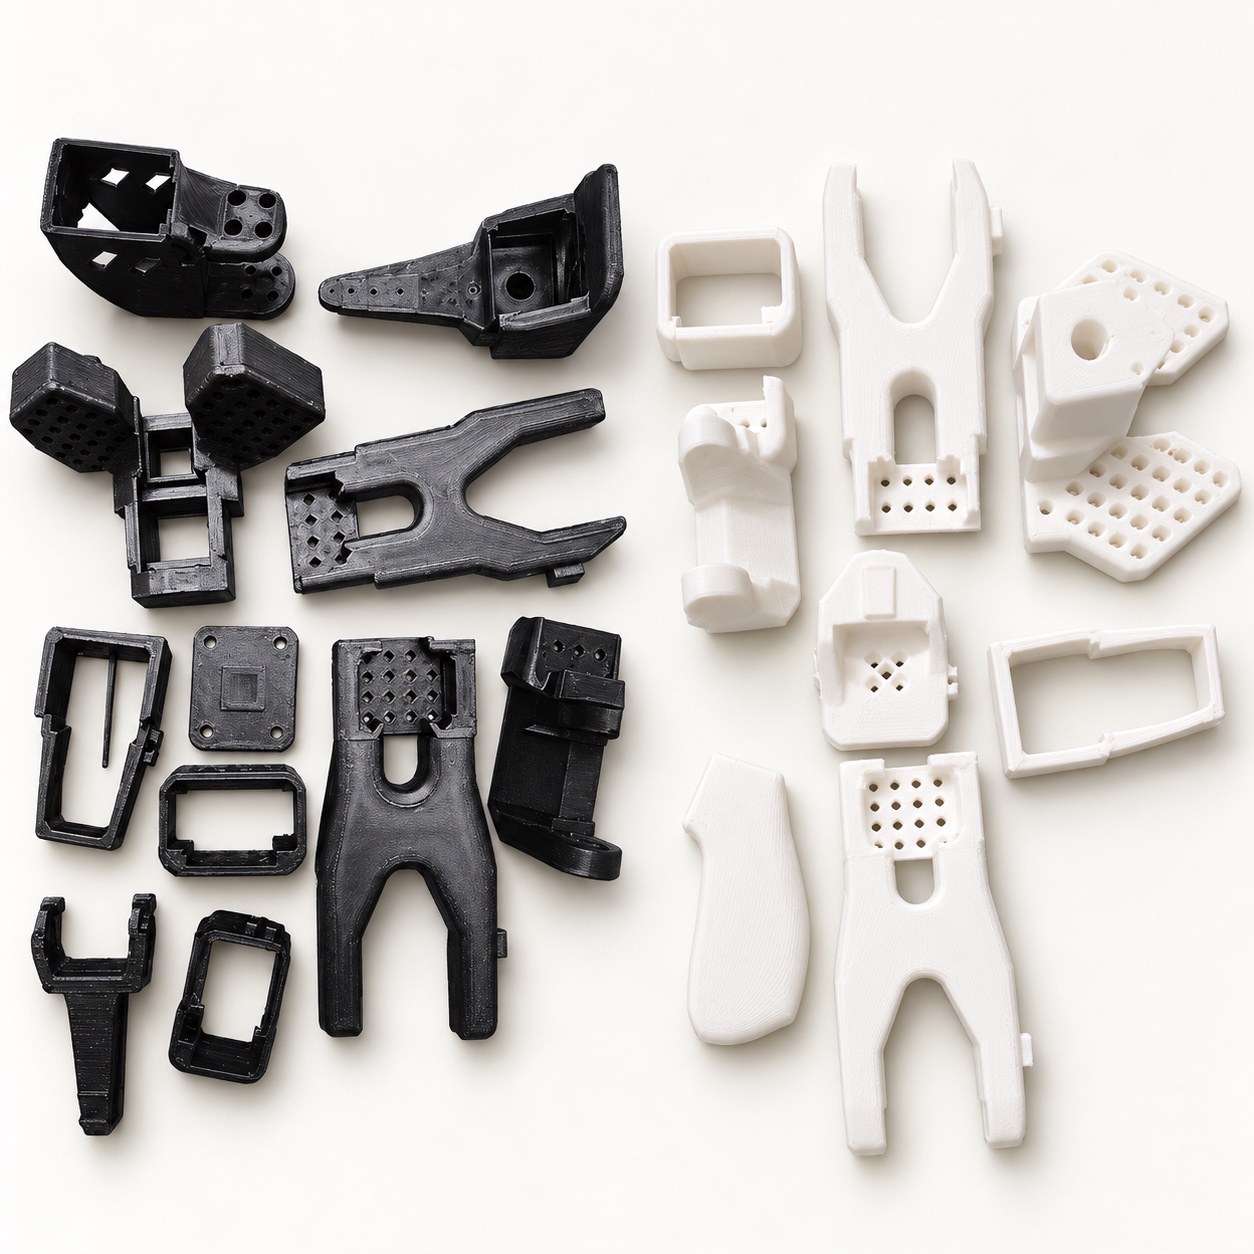
The nine common parts are supplied twice—once for the leader and once for the follower. The same WaveShare or Seeed Studio controller-board choice is used for both mounting plates.
| Qty | Printed part | Purpose in the arm |
|---|---|---|
| 2 | Base motor holderBase_motor_holder_SO101.stl | Supports the shoulder-lift motor above each arm base. |
| 2 | BaseBase_SO101.stl | Forms the lower body of each arm and houses its first joint. |
| 2 | Base motor retainerMotor_holder_SO101_Base.stl | Locks the shoulder-pan motor into each base structure. |
| 2 | Wrist motor holderMotor_holder_SO101_Wrist.stl | Retains the wrist-flex motor at the end of each forearm. |
| 2 | Forearm / under-arm linkUnder_arm_SO101.stl | Connects each elbow joint to its wrist assembly. |
| 2 | Upper-arm linkUpper_arm_SO101.stl | Connects each shoulder joint to its elbow joint. |
| 2 | Rotation-pitch bodyRotation_Pitch_SO101.stl | Forms a pitch-joint body and transfers motion between arm links. |
| 2 | Wrist roll-pitch linkWrist_Roll_Pitch_SO101.stl | Connects wrist pitch to the wrist-roll stage on each arm. |
| 2 | Controller mounting plateWaveShare_Mounting_Plate_SO101.stl or Seeedstudio_Mounting_Plate_SO101.stl | Secures the selected controller board to each arm base. |
| 1 | Moving gripper jawMoving_Jaw_SO101.stl | Acts as the follower’s moving claw for grasping objects. |
| 1 | Follower wrist-roll bodyWrist_Roll_Follower_SO101.stl | Connects the follower wrist-roll servo to its gripper assembly. |
| 1 | Leader handleHandle_SO101.stl | Provides the hand grip used to pose and control the leader arm. |
| 1 | Leader triggerTrigger_SO101.stl | Provides the finger-operated gripper command during teleoperation. |
| 1 | Leader wrist-roll bodyWrist_Roll_SO101.stl | Connects the wrist-roll servo to the leader handle and trigger assembly. |
Total: 18 shared-geometry pieces + 2 follower-specific pieces + 3 leader-specific pieces = 23. Manifest based on InfiBuild’s pinned production source revision eecbe3e. Gauges, all-in-one reference plates and optional TPU compliant-gripper files are not included.
The leader is moved by a person to demonstrate a task; the follower reproduces that motion. This paired printed-parts product is the structural starting point—not a functioning robot kit. We pin the upstream revision used for production and visually inspect the PLA+ prints before dispatch.
This is an independent fabrication service compatible with the open-source SO-101 design. InfiBuild is not affiliated with or endorsed by TheRobotStudio or Hugging Face.
Read the build guide for the difference between printed parts and the complete electronics and hardware bill of materials.