Exactly 11 printed pieces
- Nine common SO-101 structural parts
- Two follower-specific gripper parts
- Exactly one WaveShare or Seeed Studio controller plate
- PLA+ colour selected during checkout
- Support removal, visual inspection and India delivery
The 11-piece PLA+ structural set for one LeRobot-compatible SO-101 follower arm—the working robot that reproduces teleoperated motion and runs learned policies.
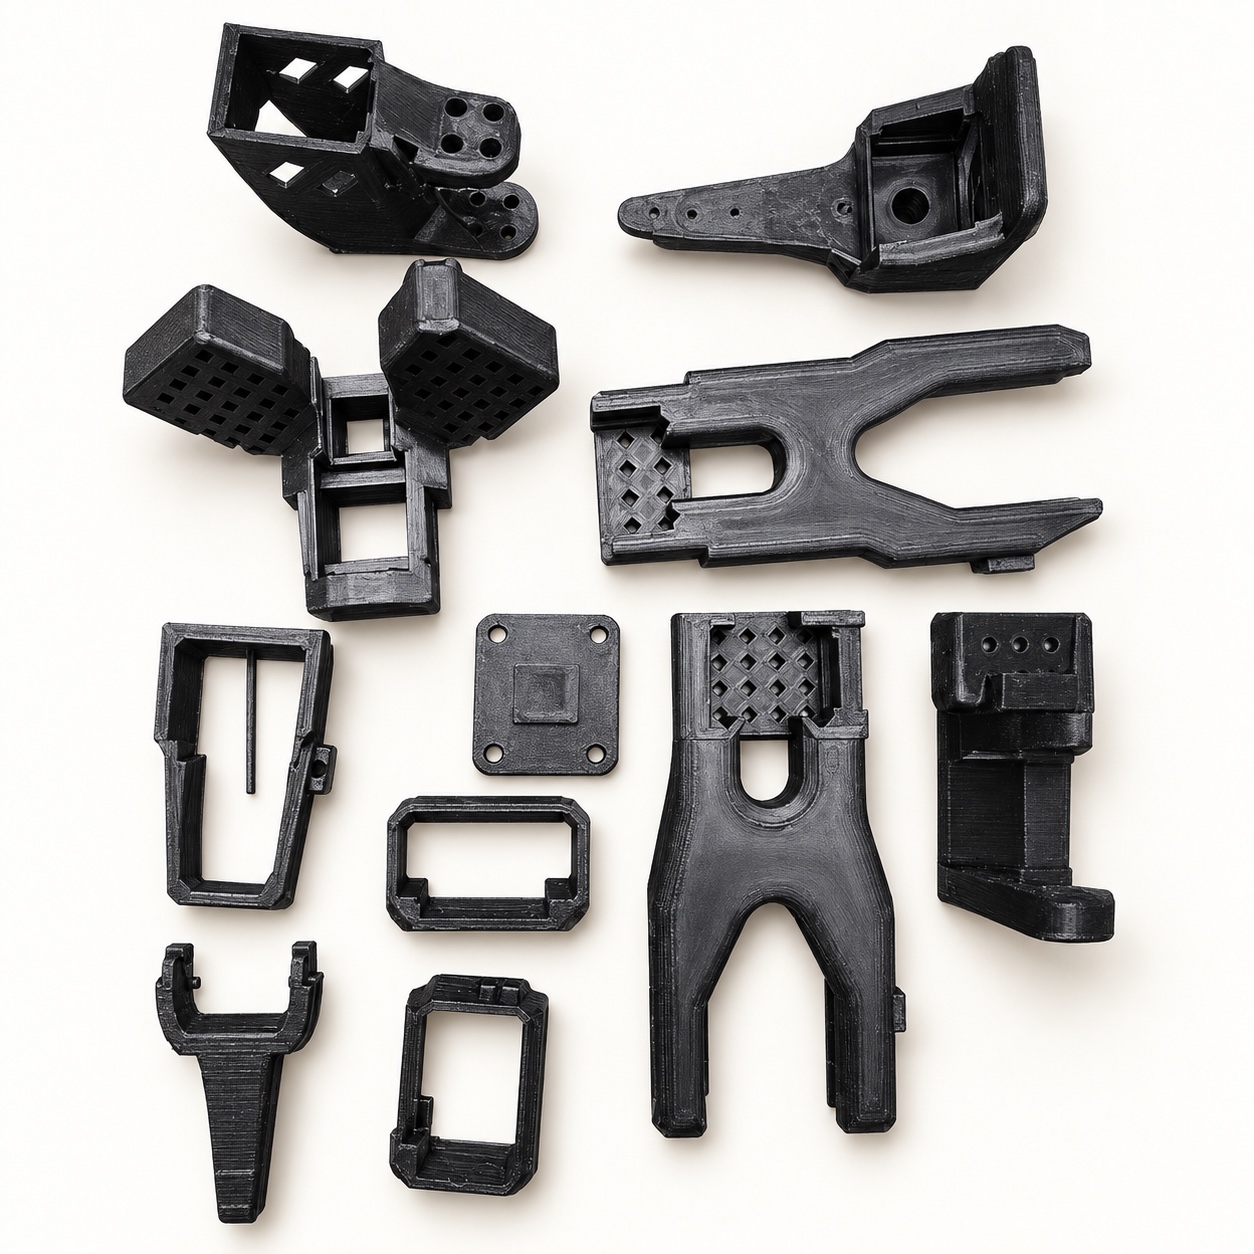
This is the exact individual-file manifest used to prepare the order. The selected controller plate replaces the other plate; it does not add a twelfth piece.
| Qty | Printed part | Purpose in the arm |
|---|---|---|
| 1 | Base motor holderBase_motor_holder_SO101.stl | Supports the shoulder-lift motor above the base. |
| 1 | BaseBase_SO101.stl | Forms the lower body of the arm and houses the first joint. |
| 1 | Base motor retainerMotor_holder_SO101_Base.stl | Locks the shoulder-pan motor into the base structure. |
| 1 | Wrist motor holderMotor_holder_SO101_Wrist.stl | Retains the wrist-flex motor at the end of the forearm. |
| 1 | Forearm / under-arm linkUnder_arm_SO101.stl | Connects the elbow joint to the wrist assembly. |
| 1 | Upper-arm linkUpper_arm_SO101.stl | Connects the shoulder joint to the elbow joint. |
| 1 | Rotation-pitch bodyRotation_Pitch_SO101.stl | Forms a pitch-joint body and transfers motion between arm links. |
| 1 | Wrist roll-pitch linkWrist_Roll_Pitch_SO101.stl | Connects wrist pitch to the wrist-roll stage. |
| 1 | Controller mounting plateWaveShare_Mounting_Plate_SO101.stl or Seeedstudio_Mounting_Plate_SO101.stl | Secures the controller board selected during checkout to the arm base. |
| 1 | Moving gripper jawMoving_Jaw_SO101.stl | Acts as the follower’s moving claw for grasping objects. |
| 1 | Follower wrist-roll bodyWrist_Roll_Follower_SO101.stl | Connects the wrist-roll servo to the follower gripper assembly. |
Manifest based on InfiBuild’s pinned production source revision eecbe3e. Gauges, all-in-one reference plates and optional TPU compliant-gripper files are not included.
The follower is the actuated arm used for teleoperation playback and autonomous tasks. We pin the upstream source revision used for production, print in PLA+, remove supports and visually inspect the set before dispatch.
This is an independent fabrication service compatible with the open-source SO-101 design. InfiBuild is not affiliated with or endorsed by TheRobotStudio or Hugging Face.
The paired set adds the leader arm used to demonstrate motion and collect training data.