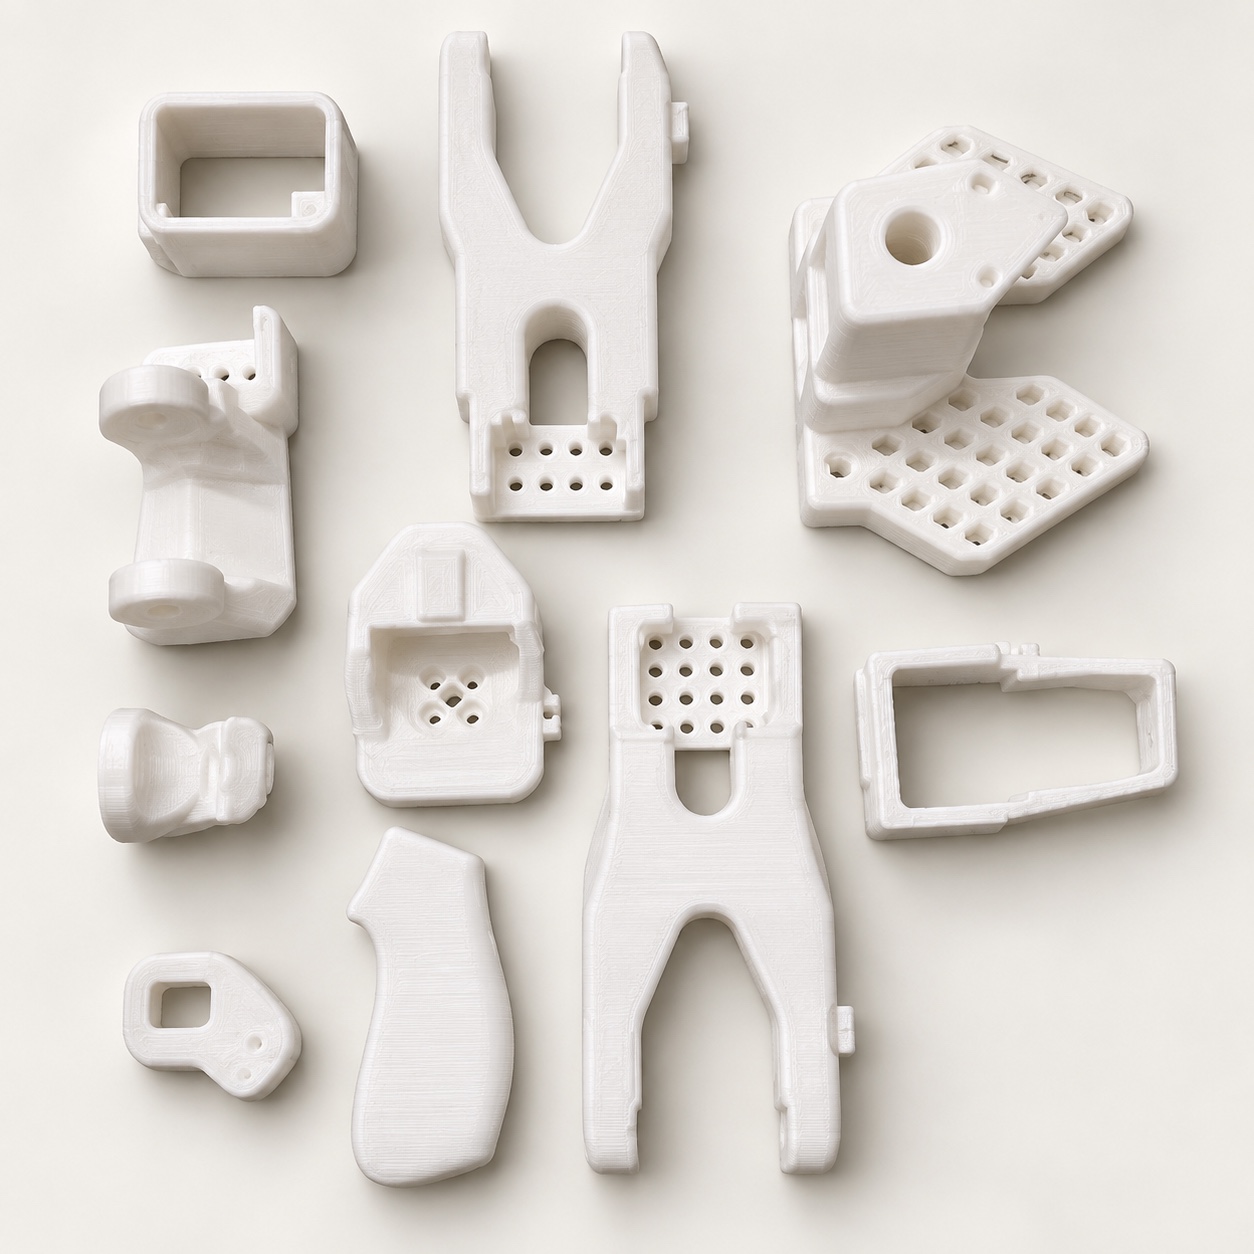
| 1 | Base motor holder
Base_motor_holder_SO101.stl | Supports the shoulder-lift motor above the base. |
| 1 | Base
Base_SO101.stl | Forms the lower body of the arm and houses the first joint. |
| 1 | Base motor retainer
Motor_holder_SO101_Base.stl | Locks the shoulder-pan motor into the base structure. |
| 1 | Wrist motor holder
Motor_holder_SO101_Wrist.stl | Retains the wrist-flex motor at the end of the forearm. |
| 1 | Forearm / under-arm link
Under_arm_SO101.stl | Connects the elbow joint to the wrist assembly. |
| 1 | Upper-arm link
Upper_arm_SO101.stl | Connects the shoulder joint to the elbow joint. |
| 1 | Rotation-pitch body
Rotation_Pitch_SO101.stl | Forms a pitch-joint body and transfers motion between arm links. |
| 1 | Wrist roll-pitch link
Wrist_Roll_Pitch_SO101.stl | Connects wrist pitch to the wrist-roll stage. |
| 1 | Controller mounting plate
WaveShare_Mounting_Plate_SO101.stl or Seeedstudio_Mounting_Plate_SO101.stl | Secures the controller board selected during checkout to the arm base. |
| 1 | Leader handle
Handle_SO101.stl | Provides the hand grip used to pose and control the leader arm. |
| 1 | Leader trigger
Trigger_SO101.stl | Provides the finger-operated gripper command during teleoperation. |
| 1 | Leader wrist-roll body
Wrist_Roll_SO101.stl | Connects the wrist-roll servo to the leader handle and trigger assembly. |